Overview
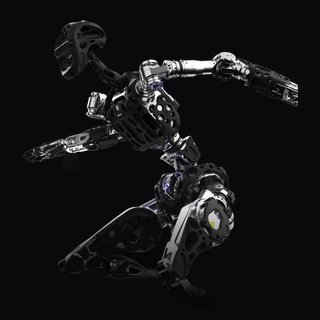
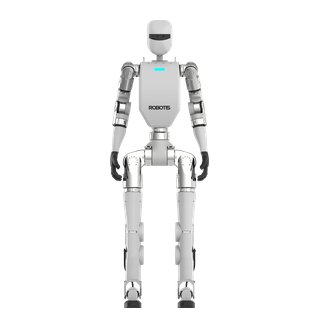
Sharpa Robotics' D01, unveiled September 28, 2026 at IROS 2026 in Pittsburgh, is a tactile-first humanoid built around the company's Wave dexterous hands and 7-DoF arms with human-scale spherical wrists. The whole body is covered in electronic skin (0.2 N force resolution, 100 Hz sampling) so it can sense contact anywhere — Sharpa demonstrated it catching a falling stick. Official spec sheet: 1,109–1,624 mm adjustable height, ~40 kg, 66 DoF with hands, 5 kg rated payload per arm at roughly a 1:1 payload-to-weight ratio, >10.5 m/s maximum end-effector speed, ±0.2 mm repeatability and up to 1,000 Hz communication, running on an NVIDIA Jetson Thor with a ROS 2-compatible, Linux-based stack. Debuted alongside the W02 hand (21 DoF, under 750 g, IP54) and the AE01 haptic exoskeleton glove for teleoperation and demonstration capture. Verification level: partial — core specs are corroborated, edge cases are maker claims. Positioned for dexterous manipulation research; manufacturing; food service; retail; hospitality. Headline numbers: 162 cm tall, 40 kg, 66 degrees of freedom, 5 kg payload, 0 of rated runtime.
Sourcing Notes
Unveiled Sept 28, 2026 at IROS 2026 (Pittsburgh), booth 514, alongside the W02 dexterous hand (21 DoF, <750 g, IP54) and AE01 haptic data glove (22 DoF, 256-level fingertip feedback). Specs from Sharpa's official D01 spec sheet.